Obstacle Avoidance Is Behavior, Not Just A Sensor
Adding sensors to a robot for obstacle avoidance begins with choosing how the robot should behave when the world gets in the way. A distance sensor, bumper switch, infrared detector, camera, or lidar-style module does not automatically make a robot intelligent. The sensor must be placed well, wired reliably, read at the right time, filtered sensibly, and connected to movement decisions that keep the robot from freezing, ramming, or turning in circles. The real project is turning measurements into behavior.
A: Start with the smallest test that proves one real part of the project.
A: Enough to know the goal, material limits, tool setup, and first safety check.
A: No. It should be clear, testable, and easy to revise.
A: Early failures usually come from voltage drops, overheated motors, loose wires, weak brackets, bad calibration, and unsafe motion.
A: Match the material to load, use, finish, cost, repair, and available tools.
A: Scale after a small test works repeatedly and the cost still makes sense.
A: Save measurements, settings, suppliers, photos, failures, and changes.
A: Rework drops, fit improves, safety is clearer, and results repeat more often.
A: Avoid hiding weak structure, unsafe setup, or unclear decisions under a nice finish.
A: It solves the intended job and teaches a better next build.
Define The Avoidance Behavior
A sensor does not decide what polite robot behavior looks like. The builder must choose whether the robot should stop, slow, reverse, turn left, scan, follow a wall, or ask for help. That behavior choice guides sensor type, placement, thresholds, and speed.
Obstacle avoidance starts as a behavior design problem before it becomes a wiring task.
Mount Sensors Where Collisions Begin
Sensors should look where trouble appears. A front sensor mounted too high may miss low blocks. A side sensor angled poorly may discover a wall only after the wheel catches. A bumper placed behind the chassis edge may never trigger in time.
Move the sensor and watch readings before writing final code. Placement is part of the intelligence.
Treat Readings As Imperfect Evidence
Ultrasonic, infrared, time-of-flight, bumper, and camera-based sensing all have blind spots. Soft fabric, shiny surfaces, narrow chair legs, strong light, angled walls, and motor noise can distort readings. One sample should rarely control a fast robot.
Filtering, repeated samples, and conservative speed help the robot behave safely around imperfect information.
Power And Wiring Affect Perception
A sensor may work beautifully while the robot sits still and fail as soon as motors run. Voltage sag, shared grounds, loose jumpers, and cable routing can corrupt readings or reset the controller. Test the full moving robot, not only the sensor module.
If behavior changes when motors start, inspect power before blaming the algorithm.
Give The Robot A Recovery Plan
Robots get trapped. Corners, narrow passages, and conflicting readings can make a simple turn-away rule loop forever. Recovery behavior might include backing up, choosing the clearer side, stopping, or scanning before moving again.
A recovery plan makes the robot feel less brittle because one awkward obstacle does not end the run.
Use A Repeatable Obstacle Course
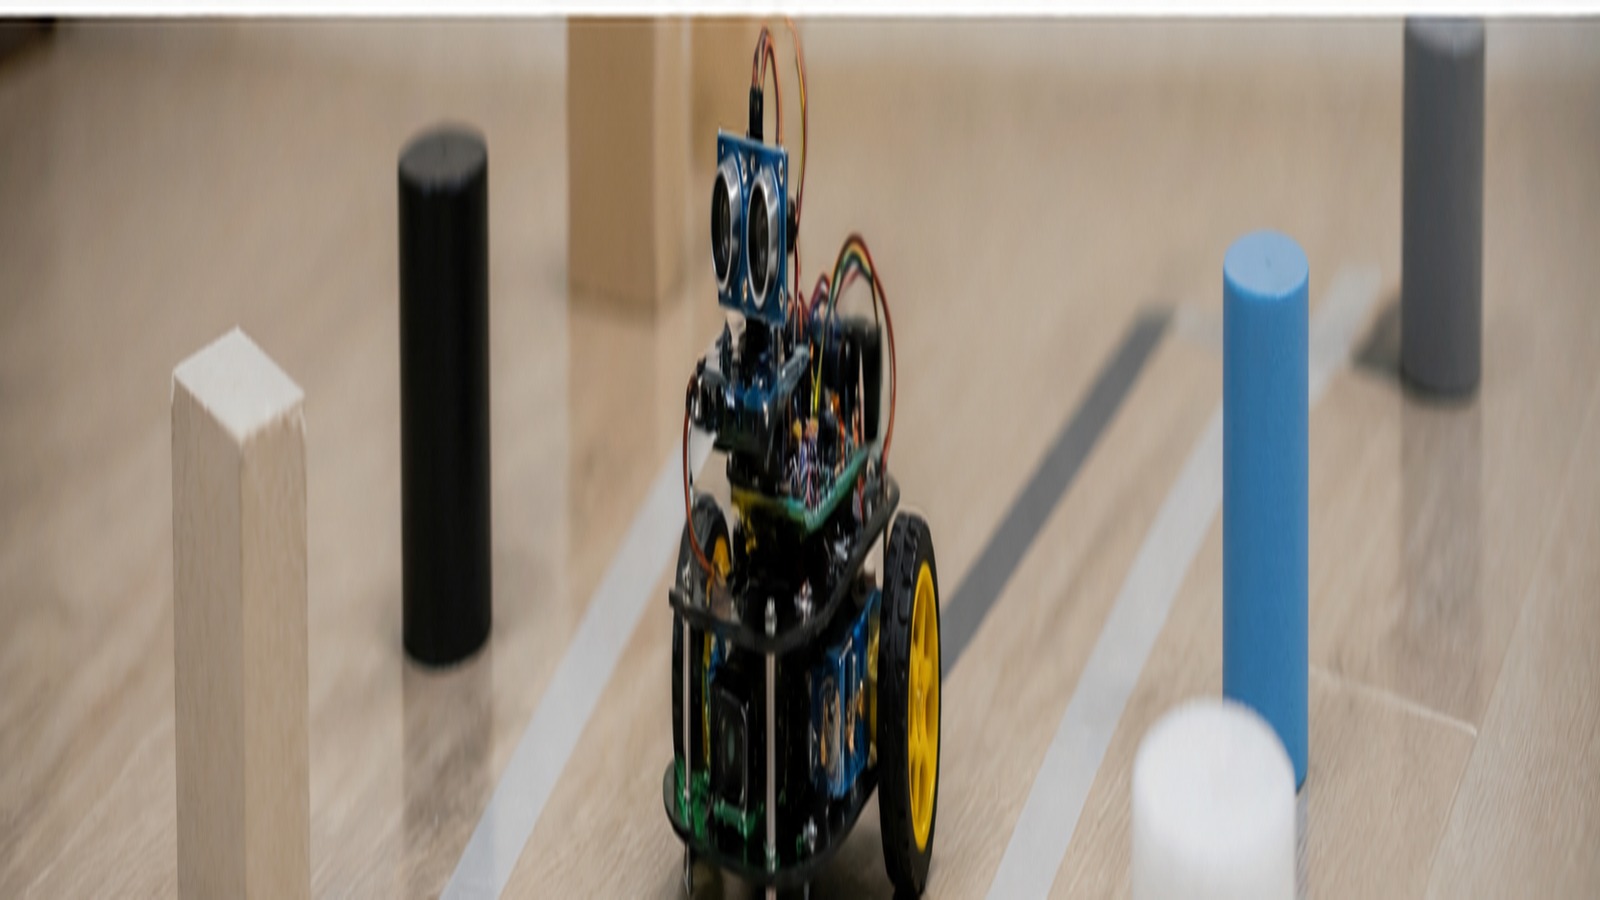
A test course with boxes, cylinders, chair legs, soft objects, and angled surfaces turns tuning into evidence. Run the same course at the same speed, change one setting, and record the behavior. This is much better than celebrating one lucky lap.
Reliable avoidance comes from repeated boring success around deliberately annoying objects.
Decide What Avoidance Means
Obstacle avoidance can mean stopping, slowing, backing up, turning, following a wall, choosing a new path, or asking for help. The sensor choice depends on that behavior. A bumper switch can stop a robot after contact, while a distance sensor can slow it before contact.
Write the desired behavior in plain language before wiring. The code becomes easier when the robot’s intended manners are clear.
Sensor Readings Are Imperfect Stories
Sensors do not report reality directly. They report measurements shaped by angle, material, light, sound, distance, noise, and timing. A soft curtain may absorb an ultrasonic pulse. A shiny object may reflect oddly. A dark surface may change infrared readings.
Good obstacle avoidance accepts uncertainty. It uses thresholds, repeated samples, fallback behavior, and safe speeds because one reading can be wrong.
Placement Changes Intelligence
The same sensor can behave smart or foolish depending on placement. Mounted too high, it may miss low obstacles. Mounted too low, it may see the floor. Mounted behind a bumper, it may detect the robot itself. Angled poorly, it may miss corners until impact.
Before writing final code, move the sensor and watch readings. Mechanical placement is part of the algorithm.
Motor Noise Can Corrupt The Plan
Robots combine sensors with motors, and motors are electrically noisy. Voltage sag, shared grounds, poor wiring, and current spikes can reset controllers or distort readings. A sensor that behaves on USB power may misbehave when wheels start moving.
Test while motors run. If readings fail only in motion, the problem may be power and wiring rather than sensor logic.
Behavior Needs Recovery
A robot that only turns away from obstacles can still get trapped in corners, oscillate between readings, or spin in place. Recovery behavior might include backing up, turning a timed amount, scanning, choosing the clearer side, or stopping safely when readings disagree.
Recovery makes the robot feel more intentional. It also prevents one bad geometry from defeating the whole project.
Test With Annoying Obstacles
Easy tests use large flat boxes. Real rooms contain chair legs, table edges, fabric, shiny surfaces, low objects, corners, cables, and moving feet. Add difficult obstacles gradually so each failure teaches one limitation.
Record what kind of obstacle caused the problem. The fix for a blind spot is different from the fix for noisy readings or excessive speed.
Match Speed To Sensing Distance
A robot must be able to stop or turn within the distance its sensors provide. If the robot moves faster than it can measure, decide, and react, obstacle avoidance becomes collision documentation. Slow the robot during early tests and increase speed only after behavior is reliable.
This relationship between speed and sensing is often more important than buying a better sensor. A modest sensor can work well when the robot’s motion respects it.
Use Filtering Without Hiding Danger
Filtering can smooth noisy readings, but too much smoothing can delay reaction. Averaging, median filters, repeated samples, and hysteresis should be tuned around safe behavior. The robot needs stable decisions, not prettified data that arrives too late.
Test filters with sudden obstacles and moving obstacles. A calm graph is not useful if the robot hits the chair.
Create A Repeatable Test Course
A repeatable course turns obstacle avoidance into measurable progress. Place objects at known distances and angles, run the robot at the same speed, and record the failure type. Then change one variable. This makes tuning less like guessing.
The course does not need to be fancy. Boxes, cylinders, chair legs, and soft objects can teach a surprising amount when used consistently.
Log Failures As Behaviors
When the robot fails, describe the behavior rather than only naming the sensor. Did it stop too late, turn the wrong way, ignore a narrow object, panic in a corner, or reset when motors started? Behavior descriptions point toward better fixes.
This turns testing into design work instead of random parameter changing. A log that says the robot missed black chair legs at speed is much more useful than a note that says the sensor was bad.
Good failure notes make the next test sharper. They also reveal whether the robot needs better hardware, better code, or simply a slower safer speed. Over several runs, those notes expose patterns that one dramatic crash can hide. That pattern is where reliable autonomy starts, because repeated behavior can finally be designed around with practical confidence.
Choose Thresholds From Measurements
Obstacle thresholds should come from measured behavior, not hopeful numbers copied from a module example. Record sensor readings at several distances, angles, surfaces, and speeds. Then choose thresholds that leave enough stopping or turning room for the actual robot.
A threshold that works on a clean desk may fail on a floor with chair legs, shadows, fabric, or glossy objects. Measurements keep tuning honest.
Give Each Sensor A Job
Multiple sensors help only when their roles are clear. A front distance sensor might slow the robot, side sensors might protect corners, and bumpers might confirm contact. If every sensor tries to control every behavior at once, the robot can become indecisive.
Clear sensor roles make code easier to read and failures easier to diagnose. When the robot turns the wrong way, the builder knows which reading should have influenced that choice.
Design For Blind Spots
Every robot has blind spots. Wheels, low bumpers, angled furniture, and narrow posts can escape a sensor’s view. Instead of pretending the blind spots are gone, map them and decide how behavior will compensate. Slower speed, side checks, bumpers, or wider turns may help.
A robot that understands its limitations through design is more reliable than one that assumes perfect perception.
Tune Movement And Sensing Together
Sensor code and motor code cannot be tuned separately forever. Acceleration, wheel slip, turn radius, braking distance, and sensor update rate all interact. A robot that avoids obstacles at low speed may crash when speed doubles because the behavior no longer has time to matter.
Increase speed gradually and retest the same course. Motion changes the meaning of every reading.
Stop Safely When Data Gets Weird
Reliable robots need a safe response for impossible readings, missing sensors, or contradictory data. Stopping may be less glamorous than clever navigation, but it protects the robot and the room. A watchdog or sanity check can prevent motors from continuing blindly.
Obstacle avoidance should prefer an awkward pause over confident collision. That bias makes early autonomous robots much easier to trust.
Combine Contact And Distance
Distance sensors warn before impact, while bumpers confirm contact when perception fails. Combining both can make a beginner robot more robust than relying on one perfect reading. The bumper should not be the main plan, but it is a useful truth signal.
This layered approach lets the robot recover from blind spots without pretending they do not exist.
Avoid Oscillation With Hysteresis
A robot can twitch when readings hover around one threshold. Hysteresis uses different points for entering and leaving a behavior, so the robot does not rapidly switch between stop and go. This small logic detail can make motion look much calmer.
Stable behavior is often created by simple rules tuned carefully.
Test After Every Mechanical Change
Moving a sensor, changing wheel size, adding a bumper, or rerouting wires can change avoidance behavior. Retest the course after mechanical edits even if the code did not change. Robots are physical systems, and physical systems keep secrets.
A short retest protects the project from old assumptions in a new body.
Make Reliability Boring On Purpose
A good obstacle-avoidance robot eventually looks boring. It slows before trouble, turns without drama, recovers from awkward corners, and stops when information is unsafe. That calm behavior is the result of many small choices: sensor placement, threshold tuning, power stability, filtering, and realistic speed.
Boring reliability is a compliment in robotics. It means the robot is no longer surviving by luck; it is following a tested relationship between perception and motion.
That reliability makes the robot ready for more interesting navigation challenges later. Once avoidance is steady, mapping, path planning, or task behavior can be added on top of a safer foundation.
The sensor project then becomes more than crash prevention; it becomes the robot’s first real conversation with its environment.
Let Safer Behavior Win
A cautious robot that pauses is easier to improve than a confident robot that crashes. Early obstacle avoidance should reward safe hesitation while the sensor model is still being tuned, because protection gives experimentation room to continue.