A Line-Following Robot Teaches The Whole Robotics Loop
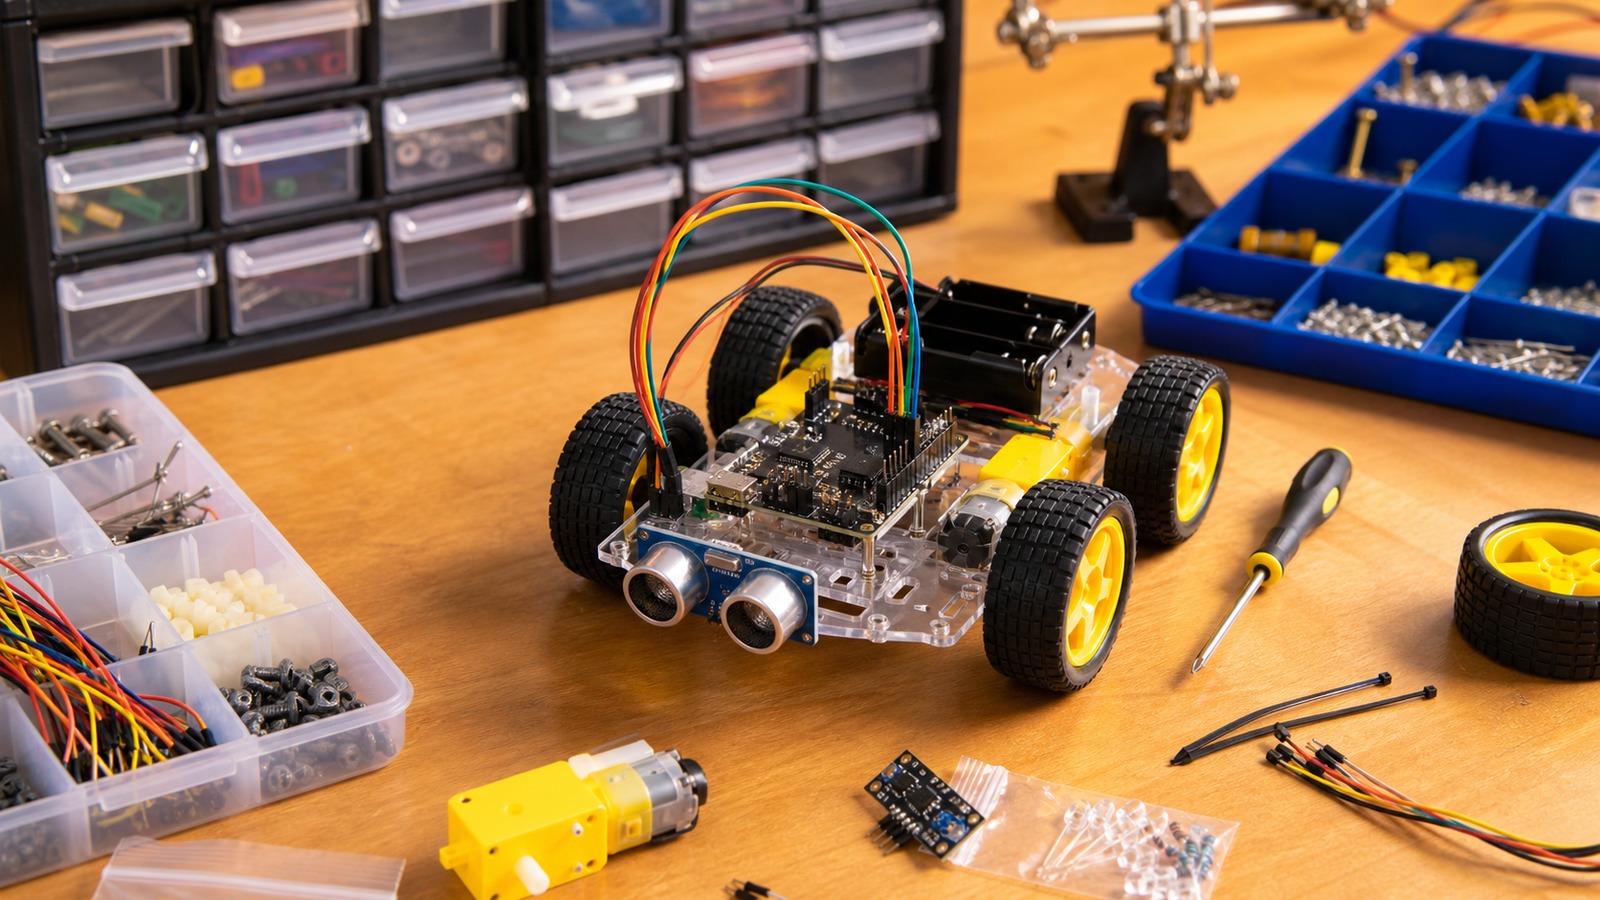
A line-following robot is one of the best beginner robotics projects because it combines mechanical building, wiring, sensors, motors, power, code, calibration, and testing in one small machine. The goal is simple: detect a dark line on a light surface and steer the wheels to stay on it. The learning is bigger than the track. You discover how physical alignment, sensor readings, motor behavior, battery strength, and control logic all affect each other.
A: Start with the smallest test that proves one real part of the project.
A: Enough to know the goal, material limits, tool setup, and first safety check.
A: No. It should be clear, testable, and easy to revise.
A: Early failures usually come from voltage drops, overheated motors, loose wires, weak brackets, bad calibration, and unsafe motion.
A: Match the material to load, use, finish, cost, repair, and available tools.
A: Scale after a small test works repeatedly and the cost still makes sense.
A: Save measurements, settings, suppliers, photos, failures, and changes.
A: Rework drops, fit improves, safety is clearer, and results repeat more often.
A: Avoid hiding weak structure, unsafe setup, or unclear decisions under a nice finish.
A: It solves the intended job and teaches a better next build.
Build The Chassis Around Straight Motion
A line-following robot does not need a fancy body, but it does need a chassis that rolls predictably. Two driven wheels and a caster or skid create a simple differential drive layout. The robot turns by driving one wheel faster than the other. If the wheels are crooked, loose, different sizes, or poorly mounted, the code has to fight mechanical problems from the first test.
Keep the chassis compact and balanced. Heavy batteries hanging off one side can make turning uneven. Loose wires can drag on the track. Sensors that shift during motion can change readings every lap. Physical reliability is the foundation of line tracking.
Place Sensors Before Writing Clever Code
Line sensors need to see the surface clearly before the wheels move past the line. Mount them near the front of the robot, close enough to the floor for stable readings but not so close that bumps scrape them. Keep their height and angle consistent. If the robot uses two sensors, spacing should match the line width and expected turns.
Read raw sensor values first. Move the robot by hand over dark line and light background and record the difference. That step tells you whether the hardware can see the track before code tries to steer.
Wire Power With Motors In Mind
Motors are noisy electrical loads. They draw startup current, create voltage dips, and can reset a controller if power is poorly planned. Use a motor driver suited to the motors and battery. Do not power motors directly from microcontroller pins. Share ground between the controller and driver when the design requires it.
Add a switch and route wires so they cannot catch in wheels. Check polarity before connecting batteries. A robot that is easy to turn off is much nicer to debug when it suddenly drives toward the edge of the bench.
If the controller resets during turns, suspect power before rewriting the whole program.
Start With Manual Motor Tests
Before line following, test each motor alone. Command the left motor forward, then backward. Do the same for the right. Confirm that forward means the robot actually moves forward and that speed control responds smoothly. Fix reversed wiring or code mappings now.
Then test both motors together on the floor without following a line. If the robot curves strongly at equal commands, there may be motor mismatch, wheel slip, friction, or weight imbalance. Small software trims can help, but mechanical issues should not be ignored.
Calibrate Dark And Light Readings
A sensor threshold separates dark line from light background. That threshold depends on sensor type, mounting height, surface reflectivity, room light, battery voltage, and the material used for the line. Calibration is the process of finding readings that match your actual track.
Use the same environment where the robot will run. A robot tuned under a desk lamp may behave differently near a window. Matte surfaces usually work better than glossy ones because reflections can confuse simple sensors.
Use Simple Steering First
The simplest line follower reads left and right sensors, then changes wheel speed. If the left sensor sees the line, slow or reverse the left wheel or speed the right wheel to steer left. If the right sensor sees the line, steer right. If both see the expected path, go forward. If neither sees the line, use the last known direction or slow down.
This logic is not elegant, but it teaches the loop. Sense, decide, move, observe, tune. Once that loop works, proportional control, sensor arrays, and smoother steering make more sense.
Tune One Variable At A Time
Line-following tuning can become chaotic if speed, threshold, sensor height, wheel trim, correction strength, and track material all change at once. Pick one variable, test it, and keep notes. If the robot overshoots curves, slow it down or reduce correction delay. If it wiggles constantly, correction may be too aggressive or sensor spacing too narrow.
Use short test tracks first. A straight line teaches whether the robot can hold direction. Gentle curves teach correction. Tight turns teach sensor placement and speed limits.
Troubleshoot With Symptoms
A robot that never starts may have power, switch, driver, or code-upload problems. A robot that spins in place may have reversed motor direction or swapped sensors. A robot that follows briefly then loses the line may be too fast, poorly calibrated, or seeing reflections. A robot that resets during turns probably has a power problem.
Name the symptom before changing parts. Robotics troubleshooting improves when each failure points to a smaller set of causes.
Improve After The First Successful Lap
Once the robot completes a lap slowly, resist the urge to rebuild everything. Improve one thing: cleaner wiring, better battery mounting, sensor shielding, smoother correction, a wider test track, or a stronger chassis. The first lap proves the system works; refinement makes it dependable.
A line-following robot is small, but it teaches the same pattern used in larger automation projects. Sensors read the world, code makes decisions, motors act, and testing reveals the gap between the plan and reality.
Choose A Track Before Final Tuning
The robot and track are a matched system. A wide matte line on a clean white board is forgiving. A thin shiny line on a reflective surface is much harder. Tight curves require slower speed, better sensor placement, or more advanced control. Before tuning code deeply, decide what kind of track the robot is meant to solve.
Use a simple practice track first. When the robot follows straight lines and gentle curves, add harder sections intentionally. This makes failures easier to understand because you know which new challenge caused the problem.
Keep The Build Serviceable
A beginner robot will be opened, rewired, adjusted, and repaired many times. Leave access to the battery, switch, motor driver, sensor screws, and controller ports. Use connectors or tidy routing where possible. Avoid burying a sensor under a chassis plate that must be removed every time calibration changes.
Serviceability is not just neatness. It keeps experimentation moving. When a fix takes five minutes instead of disassembling the whole robot, you are more likely to test thoughtfully and less likely to accept unreliable behavior.
Calibration Belongs In The Code
Hard-coded sensor thresholds can work on one bench and fail in another room. Better beginner programs include a simple calibration step or at least make threshold values easy to change. Some robots read the light surface, read the dark line, and set a midpoint. Others store values entered after testing.
This does not require advanced software. It only requires treating sensor readings as real measurements that vary. Once calibration is part of the project, the robot becomes more adaptable and easier to troubleshoot.
Speed Is The Final Upgrade
Fast line followers are impressive, but speed should come after reliability. Higher speed magnifies every weakness: sensor delay, wheel slip, poor correction, loose batteries, weak motors, and track glare. A slow robot that follows cleanly teaches more than a fast robot that leaves the line unpredictably.
Increase speed in small steps. After each change, watch where errors happen. If the robot fails only on curves, tune steering. If it fails after several laps, check battery sag or motor heat. Speed is a reward for a stable system, not the starting point.
Sensor Arrays Add More Nuance
Two sensors are enough for learning, but an array of three, five, or more sensors can detect line position with more nuance. Instead of simply seeing left or right, the robot can estimate how far it is from center. That makes smoother steering and faster curves possible when the rest of the build is ready.
Do not add sensors to hide poor basics. If two sensors cannot produce reliable readings on a simple track, an array may only create more confusing data. Upgrade sensing after mounting, lighting, and calibration are already dependable.
A Better Chassis Improves The Code
Clean code cannot fully compensate for a chassis that flexes, drags, or twists. Wheel alignment, tire grip, motor mounting, sensor bracket stiffness, and battery placement all affect the control loop. If the robot turns differently left than right, look for mechanical asymmetry before adding complicated corrections.
Small improvements can make a big difference. Tighten the motor mounts, lower the battery, shorten loose wires, align the caster, and make sure the sensors do not wobble. Better hardware often makes simpler code work.
Make The First Version Easy To Understand
A first line-following robot should be simple enough that you can explain every wire and every line of code. Use two motors, a clear driver, a small controller, a modest battery, and sensors you can read directly. Extra displays, wireless control, decorative lights, and complicated chassis features can wait until the basic loop works.
This simplicity makes troubleshooting humane. If the robot fails, there are fewer suspects. You can check sensor readings, motor direction, battery voltage, threshold values, and steering decisions without digging through unrelated features. The first version is a learning instrument as much as a robot.
After it follows reliably, then personalize it. Add a cleaner chassis, sensor array, speed control, start button, better battery mount, or smoother algorithm. The project grows best when each upgrade rests on a working foundation.
Use Failures To Improve The Course
When the robot fails at the same curve repeatedly, the track is giving useful feedback. Maybe the line is too sharp for the current speed, the sensors are too far back, the threshold is too close to room-light noise, or the robot waits too long before correcting. Change the robot or the course deliberately and test again.
Keep a small list of failure points. Straight sections, gentle curves, intersections, gaps, and sharp turns each reveal different weaknesses. A good test course grows with the robot instead of becoming a random obstacle collection.
Protect The Electronics From Motion
Robots vibrate, bump, and twist. Secure the controller, driver, battery, and sensor wires so movement does not create intermittent faults. Strain relief on battery leads and motor wires can prevent a working robot from failing after a few laps.
Use standoffs, tape, ties, screws, or printed mounts as the build allows. The robot does not need to look polished at first, but the electronics should not bounce around while the code is trying to learn the line.
Celebrate The Slow Working Lap
The first successful lap does not need to be fast. A slow robot that senses, corrects, and returns to the line is already proving the system. Speed can wait until the robot has earned it through repeatable behavior.
Small Robots Teach Big Systems
That small loop of sensing, deciding, moving, and testing is the heart of much larger automation work.